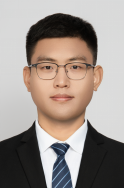
个人简介:
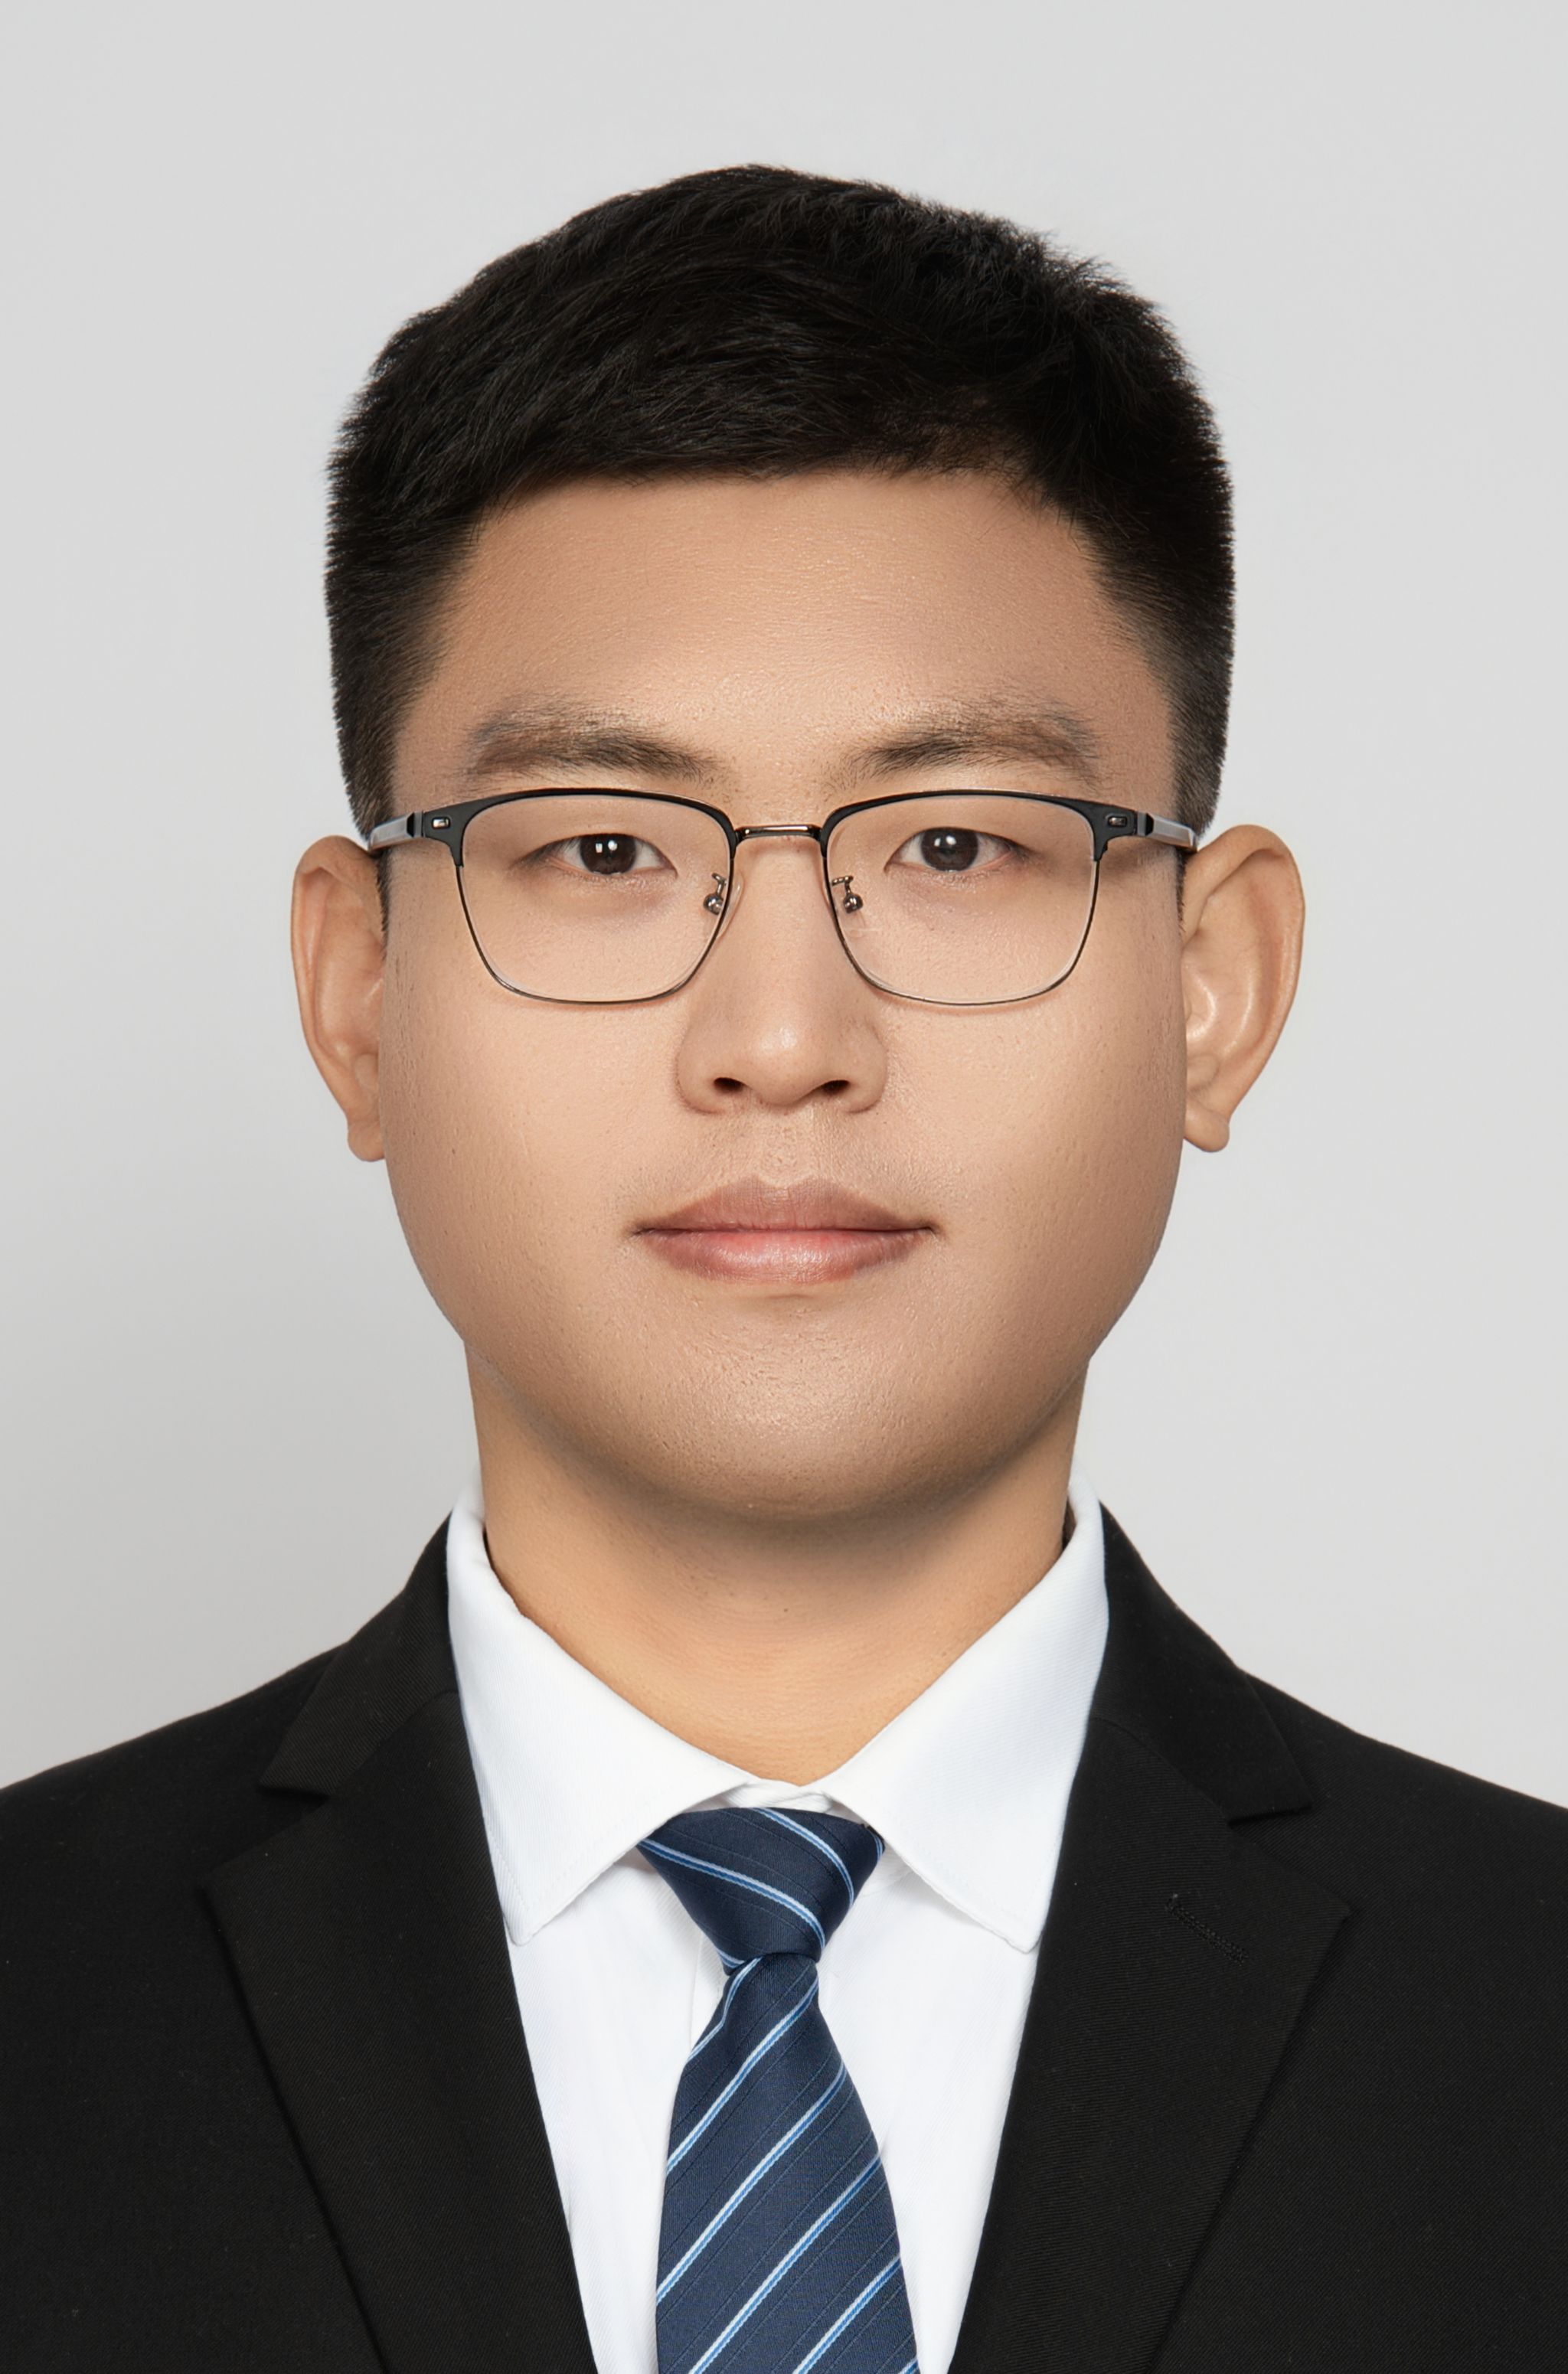
姚翔宇,河北黄骅人、民革党员,教授、机械系主任,地大学者青年拔尖人才、黄海明珠领军人才
邮 箱:yaoxy@cug.edu.cn
地 址:武汉市洪山区鲁磨路388号,地大-机电学院(教二楼)625室
主要经历:
² 2021.06-2024.03:中国地质大学,自动化学院,博士后
合作导师:何勇教授(国家杰青、长江特聘、万人领军)
² 2019.08-2020.08:韩国 Yeungnam University,电气工程系,CSC博士
博导:韩国科学院院士 Ju H. Park教授
² 2011.09-至今:中国地质大学,工学学士/工学博士/博士后/特任教授/教授/机械系主任
研究方向:
l 机器人(UAV-USV)感知(Vision-LiDAR)-规划(DRL-MPC)-控制(Game-Optimization)
学生培养:
欢迎热爱科学研究、学习积极性高、具备良好编程能力的机械、机器人、自动化、电气、通信、电信、计算机和数学等相关专业背景的同学加入,本人课题组目前有多名博士生和硕士生共同开展理论应用研究、生活工作氛围融洽和谐,承诺提供良好的科研指导和学习生活条件,且大力支持参加国内外学术会议,推荐出国留学及CSC联合培养。
v 刘文瑾(联培):赴韩国汉阳大学访学,就职武汉纺织大学
v 华梦虎(联培):获博士研究生国奖,就职湖北师范大学
v 耿梅杰(联培):CSC资助赴德国University of Duisburg-Essen控制工程首席教授,自动控制与复杂系统(AKS)研究所所长Steven X. Ding教授实验室联培
v 袁新瑞:获硕士国奖,优秀硕士论文,赴韩国汉阳大学访学,获批实验室基金,就职国家能源集团,研究方向:Optimal Control of Robotic System with Attacks
v 常泽江(联培):获硕士研究生国奖,大连理工大学任威教授课题组读博,研究方向:Advanced Control of USVs
v 李秋实(联培):就职长鑫存储,研究方向:USVs Control with Constraints
v 张瑞铭:获批实验室基金,IEEE Trans. Aerosp. Electron. Syst. 期刊论文1篇,研究方向:Secure Game of UAVs
v 熊豆:Int. J. Robust Nonlin. Contr. 期刊论文1篇,研究方向:Optimal Control of USVs
v 张亚亭:研究方向:Planning-Control of UAVs-USVs with MPC
v 张云豪(联培):控制科学与工程硕士,哈工大深圳读博,研究方向:FTC of USVs
v 杜世平:2024地大保研,获优秀学士学位论文,在审论文2篇,研究方向:Coalition Game of UAVs
v 覃泳强:2024地大保研,入选中石油计划,研究方向:Downhole Measurement Technology
v 李国政:2024地大保研,在审论文2篇,研究方向:Time-Varying Optimal Control of UAVs
v 宋欣蓉:2024山东科技大学保研,在审论文1篇,研究方向:Planning-Game of USVs with MPC
v 梅雨轩:本科毕业于地大自动化,在审论文2篇,研究方向:DRL Game of USVs
v 张展鹏:本科毕业于地大自动化,在审论文1篇,研究方向:Uncertain Games
v 尤印莉:2025湖北工业大学保研,在审论文2篇,研究方向:DRL Game of UAVs
v 华成栋、杨羽作:研究方向:Machine Vision and Applications for UAVs
v 万家宇越:2026湖北工业大学保研,研究方向:DRL Planning-Game of UAVs
v 杨耀东:2026武汉工程大学保研,研究方向:Perception-Planning-Control of UAVs
v 邹贻媛:2026昆明理工大学保研,研究方向:DRL Planning-Game of UAVs
v 刘思成:研究方向:Perception-Planning of UAVs
v 史慧敏(联培):低空技术与工程硕士,本科毕业于地大电子信息,研究方向:DRL Planning-Game of UAVs
v 曾杰:获2025年优秀学士学位论文
v 燕志宸:获2023年优秀学士学位论文
部分成果:
Ø Xiang-Yu Yao, J. H. Park, H. Ding, M. Ge, Event-triggered consensus control for networked underactuated robotic systems. IEEE Transactions on Cybernetics, 2022, 52(5): 2896-2906. (高被引论文)
Ø Xiang-Yu Yao, J. H. Park, H. Ding, M. Ge, Coordination of a class of underactuated systems via sampled-data-based event-triggered schemes. IEEE Transactions on Systems, Man, and Cybernetics: Systems, 2022, 52(4): 2156-2166.
Ø M. Geng, Steven X. Ding, D. Liang, Xiang-Yu Yao*, Distributed game-theoretic control of multi-QAAV under nonlinear constraints and unknown actuator faults, IEEE Transactions on Aerospace and Electronic Systems, 2026, doi: 10.1109/TAES.2026.3725666.
Ø M. Hua, Xiang-Yu Yao*, W. Liu, C. Liang, J. H. Park, M. Ge, Distributed fixed-time time-varying games for autonomous surface vehicles, IEEE Transactions on Vehicular Technology, 2026, doi: 10.1109/TVT.2026.3692349.
Ø M. Geng, Steven X. Ding, Xiang-Yu Yao*, X. Yuan, Hybrid-triggered constrained optimal coordination of faulty robotic manipulators with cyber attacks, Control Engineering Practice, 2026, 173: 107012.
Ø R. Zhang, Xiang-Yu Yao*, L. Wang, J. H. Park, M. Ge, Distributed fault-tolerant formation game for quadrotor UAVs with hybrid attacks, IEEE Transactions on Aerospace and Electronic Systems, 2025, 61(5): 11338-11349.
Ø M. Hua, Xiang-Yu Yao*, W. Liu, M. Geng, M. Lv, Optimizing fixed-time generalized Nash equilibrium seeking in multi-unmanned aerial vehicle games, IEEE Transactions on Aerospace and Electronic Systems, 2025, 61(3): 6339-6353.
Ø M. Geng, H. Ding*, Xiang-Yu Yao*, M. Lv, Resilient distributed quadrotor AAVs game: Addressing FDI and physical attacks, IEEE Transactions on Vehicular Technology, 2025, 74(8): 13029-13040.
Ø M. Geng, H. Ding*, Xiang-Yu Yao*, W. Liu, M. Hua, Noncooperative game of distributed quadrotor UAVs with multiple constraints, IEEE Transactions on Aerospace and Electronic Systems, 2024, 60(4): 4728-4739.
Ø Z. Chang, Xiang-Yu Yao*, J. H. Park, Fixed-time formation tracking of multiple USVs with DoS attacks: A reinforcement learning control method, International Journal of Robust and Nonlinear Control, 2026, 10.1002/rnc.70674.
Ø W. Liu, Y. Wang, Xiang-Yu Yao*, X. Zhang, Y. Zhang, M. Ge, Task-space Nash equilibrium seeking in multiple Lagrangian systems with generally quadratic time-varying objectives, Information Sciences, 2026, 756: 123835.
Ø Z. Chang, Xiang-Yu Yao*, Y. Zhang, J. H. Park, Multi-layer NN-based fixed-time distributed optimisation for coordinated dynamic positioning of unmanned surface vehicles. International Journal of Control, 2026, 99(4): 966-984.
Ø Xiang-Yu Yao, J. H. Park, H. Ding, M. Ge, Quantized fault-tolerant consensus for multiple Lagrangian systems subject to switching networks, International Journal of Robust and Nonlinear Control, 2021, 31(11): 5069-5085.
Ø Xiang-Yu Yao, J. H. Park, H. Ding, M. Ge, Event-triggered fault-tolerant control for nonlinear systems with semi-Markov process, International Journal of Control, 2022, 95(9): 2315-2325.
Ø D. Xiong, Xiang-Yu Yao*, J. H. Park, M. Ge, Distributed event-triggered optimization for multiple usvs with coupled objective functions, International Journal of Robust and Nonlinear Control, 2025, 35(13): 5717-5729.
Ø W. Liu, Xiang-Yu Yao*, M. Hua, J. H. Park, M. Ge, Distributed Nash equilibrium seeking for multi-coalition games with constrained NASVs: A hierarchical prescribed-performance algorithm, Neurocomputing, 2025, 650: 130821.
Ø M. Hua, Xiang-Yu Yao*, W. Liu, Fully distributed fixed-time optimisation for multiple Euler-Lagrange systems, International Journal of Control, doi: 10.1080/00207179.2025.2518177.
Ø Z. Chang, Xiang-Yu Yao*, J. H. Park, Fixed-time formation tracking for unmanned surface vehicles: A multi-layer neural networks approach. Neurocomputing, 2024, 600: 128220.
Ø X. Yuan, Xiang-Yu Yao*, J. H. Park, M. Ge, Resilient event-triggered fault-tolerant optimization for Euler-Lagrange plants with intermittent communication and asynchronous DoS attacks. International Journal of Robust and Nonlinear Control, 2024, 34(8): 5190-5211.
Ø X. Yuan, Xiang-Yu Yao*, M. Ge, Y. Li, Event-triggered fault-tolerant optimal coordination for multiple Euler–Lagrange systems with semi-Markov jumping networks. International Journal of Control, 2024, 97(10): 2353-2364.
Ø Xiang-Yu Yao, H. Ding, M. Ge, J. H. Park, Event-triggered synchronization control of networked Euler-Lagrange systems without requiring relative velocity information, Information Sciences, 2020, 508: 183-199.
Ø Xiang-Yu Yao, H. Ding, M. Ge, Fully distributed control for task-space formation tracking of nonlinear heterogeneous robotic systems, Nonlinear Dynamics, 2019, 96(1): 87-105.
Ø Xiang-Yu Yao, H. Ding, M. Ge, Task-space tracking control of multi-robot systems with disturbances and uncertainties rejection capability. Nonlinear Dynamics, 2018, 92(4): 1649-1664.
Ø Xiang-Yu Yao, H. Ding, M. Ge, Synchronization control for multiple heterogeneous robotic systems with parameter uncertainties and communication delays, Journal of The Franklin Institute, 2019, 356(16): 9713-9729.
Ø Xiang-Yu Yao, H. Ding, M. Ge, Formation-containment control for multi-robot systems with two-layer leaders via hierarchical controller-estimator algorithms, Journal of The Franklin Institute, 2018, 355(12): 5272-5290.
Ø W. Liu, R. Cao, Xiang-Yu Yao, X. Zhang, M. Ge, Efficient game-based homeward coordination for connected autonomous aerial vehicles through a distributed bilevel event-based algorithm, IEEE Transactions on Aerospace and Electronic Systems, 2026, 62: 14587-14599.
Ø W. Liu, M. Hua, M. Ge, Xiang-Yu Yao, Z. Liu, least-distance formation control for a class of connected autonomous engineering vehicles under multilayer attacks, IEEE Transactions on Vehicular Technology, 2025, 74(12): 18597-18609.
Ø Y. Li, Q. Geng, Z. Guan, Xiang-Yu Yao, C. Hua, Fully distributed leader-following consensus of nonlinear multiagent systems: An output-dependent dynamic gain method. IEEE Transactions on Systems, Man, and Cybernetics: Systems, 2024, 54(4): 2452-2461.
Ø Y. Li, W. Liu, Xiang-Yu Yao, H. Dong, M. Ge, Game-based robust formation approaches for networked autonomous surface vessels with input dead-zone and decision-making constraints, International Journal of Robust and Nonlinear Control, 2026, 36(15): 7294-7308.
Ø W. Liu, R. Cao, X. Zhang, Xiang-Yu Yao, M. Ge, Distributed nonlinear placement problems in the NASVs with nonsmooth objectives and unknown time-varying actuator faults, Ocean Engineering, 2026, 362: 126219.
Ø M. Geng, H. Ding, Xiang-Yu Yao, M. Hua, W. Liu, Event-based distributed formation-containment control for networked Euler-Lagrange systems with compound constraints. International Journal of Control, 2025, 98(8): 1924-1937.
Ø W. Liu, Xiang-Yu Yao, M. Ge, M Hua, H Ding, Hierarchical nash equilibrium seeking strategies of quadratic time-varying games with Euler-Lagrange players, International Journal of Robust and Nonlinear Control, 2024, 34(1): 666-680.
Ø M. Hua, Xiang-Yu Yao, W. Liu, H. Ding, Nonsingular fixed-time fault-tolerant control for multiple Euler-Lagrange systems without continuous communication. International Journal of Robust and Nonlinear Control, 2024, 34(4): 2532-2552.
Ø M. Hua, Xiang-Yu Yao, W. Liu, H. Ding, J. H. Park, Fixed‐time consensus of networked Euler-Lagrange systems over event‐based communication under DoS attacks. International Journal of Robust and Nonlinear Control, 2024, 34(12): 7992-8012.
Ø W. Liu, Xiang-Yu Yao, M. Ge, M. Hua, H. Ding, Hierarchical Nash equilibrium seeking strategies of quadratic time-varying games with Euler-Lagrange players. International Journal of Robust and Nonlinear Control, 2024, 34(1): 666-680.
Ø M. Hua, H. Ding, Xiang-Yu Yao, W. Liu, Distributed fixed-time Nash equilibrium seeking algorithm for multiple ASVs: A hybrid event-triggered approach. Ocean Engineering, 2023, 290: 116410.
Ø W Liu, H Ding, Xiang-Yu Yao, M. Ge, M Hua, Nonlinear placement for networked Euler-Lagrange systems: A finite-time hierarchical approach. International Journal of Robust and Nonlinear Control, 2023, 33(5): 3129-3145.
Ø W. Liu, H. Ding, M. Ge, Xiang-Yu Yao, Cooperative control for platoon generation of vehicle-to-vehicle networks: A hierarchical nonlinear MPC algorithm. Nonlinear Dynamics, 2022, 108(4): 3561-3578.
Ø X. Zhang, M. Li, H. Ding, Xiang-Yu Yao, Data-driven tuning of feedforward controller structured with infinite impulse response filter via iterative learning control, IET Control Theory & Applications, 2019, 13(8): 1062–1070.
Ø C. Liang, L. Wang, Xiang-Yu Yao, Z. Liu, M. Ge, Multi-target tracking of networked heterogeneous collaborative robots in task space, Nonlinear Dynamics, 2019, 97(2): 1159–1173.
Ø M. Hua, H. Ding, Xiang-Yu Yao, X. Zhang, Distributed fixed-time formation-containment control for multiple Euler-Lagrange systems with directed graphs, International Journal of Control, Automation and Systems, 2021, 19(2): 837-849.
² 国自然青基, 2024.01-2026.12, 主持.
² 湖北自科青基, 2023.07-2025.06, 主持.
² 中国博后面上, 2021.08-2023.08, 主持.
² 湖北博后创新研究, 2021.08-2023.08, 主持.
² 中央高校青年拔尖人才科研专项资助, 2021.06-2026.06, 主持.
² 系统控制与信息处理教育部重点实验室基金, 2023.01-2025.12, 主持.
² 智能输送技术与装备重点实验室基金, 2025.04-2026.09, 主持.
² 国自然重点, 混杂智能无人系统的自主协同与博弈, 2023.01-2027.12, 参与.
² NRFK, Regional Leading Research Center (RLRC) for Autonomous Vehicle Parts and Materials Innovation, 2019.09.01-2026.02.28, 参与.
² NRFK, Development of New Algorithms for Selecting Pinned Nodes of Networked Systems, 2017.03.01-2020.02.28, 参与.
² NRFK, Brain Korea 21 Plus: Development of Advanced Smart Mechatronics Systems, 2013.09.01-2020.02.28, 参与.
² 优秀博士创新基金, 复杂机器人网络系统协同运动控制技术, 2019.06-2021.05, 主持.
² CSC博士联培, Event-triggered control of robotic systems, 2019.08-2020.08, 主持.
² 湖北重大科技创新, 人机协作型移动式双臂作业机器人研发及应用验证, 2019.01-2021.12, 参与.
v 姚翔宇, 等, 一种四自由度并联机器人机构1, 2019-07-23, ZL201610867643.5.
v 姚翔宇, 等, 一种提升负载能力的两自由度并联机构, 2018-10-12, ZL201610989566.0.
v 姚翔宇, 等, 一种保持钻杆位姿平衡的海洋钻井装备, 2019-06-28, ZL201611161273.X.
v 姚翔宇, 等, 海上钻井设备, 2018-5-1, 中国, ZL201610643410.7.
v 姚翔宇, 等, 一种提升负载能力的2R两自由度并联机构, 2019-9-17, ZL 201610989565.6.
v 姚翔宇, 等, 一种四自由度并联机器人机构2, 2019-3-22, ZL 201610867406.9.
v 姚翔宇, 等, 六轴串联机器人运行监控系统软件V1.0, 2017SR039472, 2016-12-14.
v 姚翔宇, 等, 八档自动变速器运行监测系统V1.0, 2017SR178412, 2017-1-5.
v 姚翔宇, 等, 海洋钻井船运动参数采集系统软件V1.0, 2016SR330377, 2016-8-31.
l Session Chairs of 2025 2nd International Symposium on IoT and Intelligent Robotics, 2023 6th International Conference on Industrial Cyber-Physical Systems, 2022 6th International Conference on Robotics and Automation Sciences.
l Reviewer of IEEE Trans. Cybern., IEEE Trans. Neur. Net. Learn. Syst., IEEE Trans. Syst., Man Cybern. Syst., IEEE Trans. Ind. Inform., IEEE Trans. Ind. Electron.、IEEE Trans. Fuzzy Syst.、IEEE Trans. Intell. Veh. et al.
n 获评优秀硕士论文指导教师(2025)、优秀学士论文指导教师(2023, 2024, 2025)、优秀博士学位论文(2021)、五四青年奖章(2020)等若干荣誉奖励,受国家留基委资助留学(2019-2020)。
湖北省武汉市鲁磨路388号中国地质大学(武汉)机械与电子信息学院
027-67883273
版权所有:©中国地质大学(武汉)机械与电子信息学院 All Rights Reserved